Disembodied Robotic Hand Crawls and Manipulates Objects Independently
Researchers at ETH Zürich have developed an independent robotic hand that can move across surfaces and manipulate objects without a body. The invention addresses robotics challenges in confined spaces.
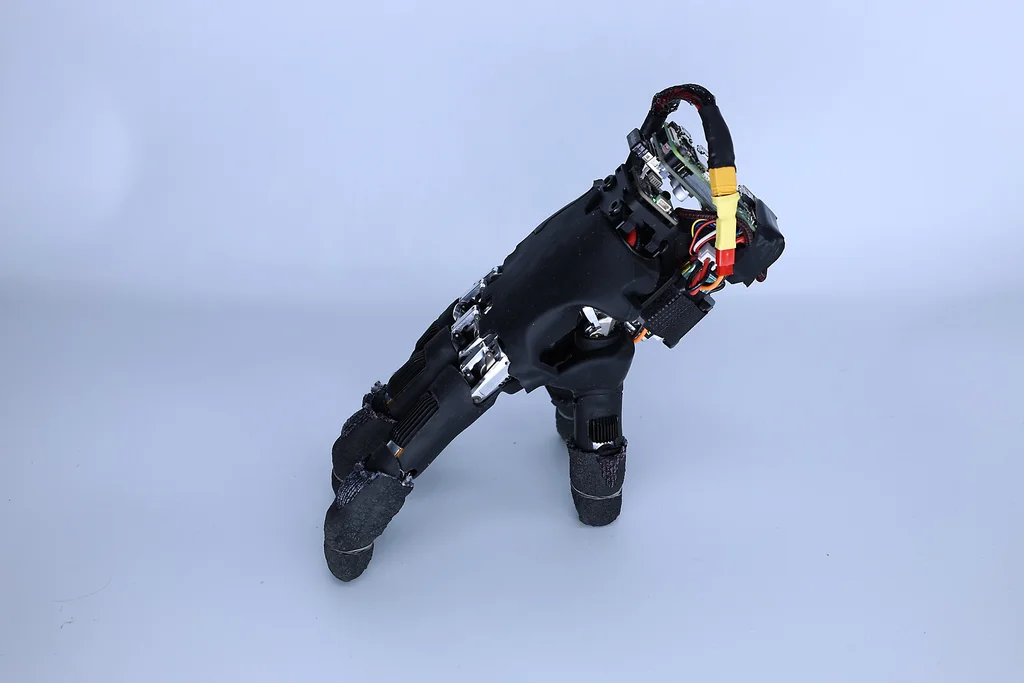
Researchers at ETH Zürich's Soft Robotics Lab have developed a self-contained robotic hand capable of crawling across surfaces and manipulating objects without being attached to a larger robotic body. Partially inspired by the character Thing from "The Addams Family," this advancement aims to enable more sophisticated robotic operations in environments where traditional arms are impractical.
Unlike typical robotic hands fixed to a mechanical arm, this hand functions as an independent unit. It can balance its own weight and utilize its five digits for both locomotion and object interaction. PhD candidate Amirhossein Kazemipour, alongside Hehui Zheng and Robert Katzschmann, detailed the invention in a paper addressing the long-standing dilemma of creating systems that can move and dexterously interact with objects simultaneously.
This development tackles issues faced when autonomous systems need to operate in cramped spaces, such as inside damaged buildings or complex pipe networks. Previously, such tasks often required cumbersome mechanical booms or bulky rovers. The new hand's ability to independently navigate tight openings offers a potential solution.
The team employed deep reinforcement learning to create an AI software that manages the hand's complex movements. The system compensates for the hand's natural asymmetry, enabling balanced locomotion. The hand is equipped with a small onboard computer, an inertial measurement unit, and a battery, making it a fully untethered and independent platform weighing just under two pounds.
In testing, the robotic hand successfully traversed various terrains and demonstrated manipulation capabilities by pressing keys on a keyboard. This independent mobility and manipulation could open new applications for robotics in hazardous environments or for tasks requiring high dexterity in confined areas.